Repo · Creative & generative UI
Jev Drone
Explore control decisions for a quadrotor.
Open github.com ↗From the repository
Camera-only autonomous drone in MuJoCo with a small judgment model (TypeSafe Jev) in the loop at 2.5Hz
autonomous-agentsdronemujocoroboticstypesafe
How builders describe it
Camera-only autonomous drone in MuJoCo with a small judgment model (TypeSafe Jev) in the loop at 2.5Hz.
Study typed Jev judgments inside a MuJoCo quadrotor simulation, with perception and fast flight control implemented separately in Python.
A simulated drone that asks Jev for a judgment 2.5 times a second.
A camera-only MuJoCo quadrotor that uses Jev for tactical maneuvers at 2.5 Hz while classical perception and a 50 Hz reflex layer keep safety outside Jev, clearing a five-station course.
The decision Jev makes
Pick the next musical direction, visual option or UI component.
Where it fits
Using repeated small choices to steer something creative: music, pixel art, layouts and interfaces that assemble themselves from a fixed vocabulary. All 69 creative & generative ui projects →
Related projects
 Creative & generative UIjev-remix-cutterIndependent Agent Skill and Python CLI for local video remixing: shot awareness, beat/narration slots, TypeSafe Jev judgments, constrained assembly,…GitHub · ★ 13 · gnipbao
 Creative & generative UIMishLocal-first AI design workspace: write a brief and a local agent CLI builds the design; in the agency fast lane, TypeSafe Jev routes the brief to a…GitHub · ZeroSum-Solutions
 Creative & generative UIjev-shorts-editorA Jev-based shorts editor.GitHub · ★ 4 · misbahsy
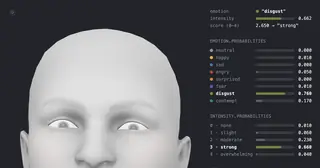 Creative & generative UIjev-face (Imjungjuna)A 3D face in the browser that reacts in real time to typed text: TypeSafe Jev judges recipient emotion and strength, driving ARKit blendshapes on a…GitHub · Imjungjuna
 Creative & generative UITHE HUNDRED EYESInteractive media artwork where one post meets 100 fictional observers: for each observer the app asks Jev one Choice plus four Score questions (500…GitHub · ★ 1
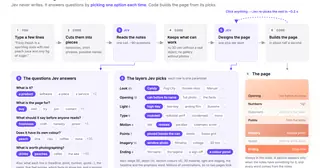 Creative & generative UIJev PagesA landing page designs itself as you type about your product.GitHub · ★ 11 · sagapranav