Repo · Home, robots & devices
quackd
Multi-robot CLI: LLM pilots pick one allowed skill per turn from adapter manifests; optional --jev puts TypeSafe Jev in front as a discrete stepper…
Open github.com ↗How builders describe it
Multi-robot CLI: LLM pilots pick one allowed skill per turn from adapter manifests; optional --jev puts TypeSafe Jev in front as a discrete stepper for closed-set verb choices (off by default).
If you have a LeRobot SO-101 at home, you can put Jev on it with quackd CLI. The setup takes about 5 minutes if you're familiar with the LeRobot. The "--jev on" parameter sits in front of the model and takes the discrete steps (read state, gripper, stop). Angles stay with the LLM. On the steps Jev…
The decision Jev makes
Choose the device action or control input from the safe options.
Where it fits
Jev deciding things in the physical world: smart-home actions, robot and drone control, and devices that need an answer in milliseconds. All 20 home, robots & devices projects →
Related projects
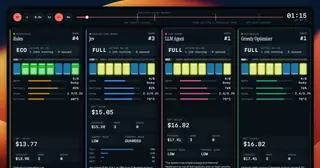 Home, robots & devicesA data center optimizerJev at the centre of a data center optimization build.X post · dr_chrisjonesHome, robots & devicesA voice assistant with no wake wordIt decides from context whether to interject at all.X post · StingCloudLab
 Home, robots & devicesOmniJevMultimodal Jev for robot decision-making.GitHub · Iron-LYK
 Home, robots & devicesunawair v3, a rule engine after JevTrying Jev led to a rule-based engine with better temperature response.X post · toowitter
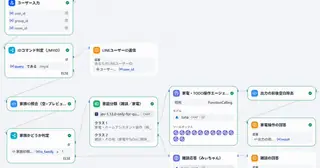 Home, robots & devicesA family-only LINE bot for the houseLights and AC by chat, with Jev keeping the cost down.X post · yo_ta_n
 Home, robots & deviceshome-assistant-typesafeHome Assistant routes what you said through Jev, not an LLM.GitHub · Allen Porter